Pittsburgh, PA · Summer 2027 internships
Robotics Software Engineer.Building intelligent machines.
I spent four years at Venti Technologies, an MIT spinoff, building the C++ navigation stack for self-driving trucks operating in seaports and rail yards. Now pursuing an MS in Robotic Systems Development at Carnegie Mellon University, I'm expanding my focus to learning-based perception, computer vision, and motion planning.
I'm seeking Summer 2027 internships in robotics software and machine learning, where I can combine real-world autonomy experience with emerging learning-based approaches.
Away from robots, I play squash, recently got into scuba diving, and watch sitcoms.
Tools I use
Skills
- C++
- Python
- ROS1 / ROS2
- PyTorch
- Nav2
- Bazel
- Docker
- Git
- Linux
School
Education
Carnegie Mellon University
Aug 2026 – May 2028Pittsburgh, PA
MS, Robotic Systems Development
Coursework in progress: Robot Mobility, Robot Autonomy, Deep Learning.
Nanyang Technological University
2018 – Jun 2022Singapore
BEng, Mechanical Engineering with Honours (Highest Distinction)
Robotics and Mechatronics specialization, entered early among the top 10% of the cohort.
Minor in Computing and Data Analysis.
Dean's List Scholar, AY19/20.
Industry
Experience
Venti Technologies
SingaporeMIT spinoff founded by Daniela Rus. Joined at fewer than 20 people; now 100+. Autonomous vehicle logistics for seaports, railyards, and industrial hubs.
- Senior Software Engineer, Planning and ControlJul 2025 – Aug 2026
- Software Engineer, Planning and ControlJul 2022 – Jul 2025
- Built the perpendicular-parking and dynamic reverse path planning features for non-holonomic truck-trailers, and took the parking planner from around 60 seconds to under 500 milliseconds.
- Co-built a 3-person remote operations system using MQTT and Cap'n Proto, and a route recommendation feature from live sensor feeds.
Panasonic R&D Center
SingaporeAutonomous mobile robots for hospitals and assisted mobility.
- Research Intern, Autonomous Mobile Robot NavigationJan 2021 – Aug 2021
- Migrated an autonomous wheelchair and a medication-delivery robot from ROS1 to ROS2 in about two months against a six-month estimate.
- Integrated Nav2 with region-based speed regulation and added Dubins-path docking for autonomous charging.
Earlier internships — Whizz Mobility, HOPE Technik2019 – 2020
Whizz Mobility
SingaporeAutonomous food-delivery robots.
- Mechatronics and Operations InternJun 2020 – Aug 2020
- Modeled the chassis, wheels, and motors of an autonomous food-delivery robot in Fusion 360, created production drawings, and helped assemble the robot in 40 days.
- Designed and 3D-printed several versions of a self-opening food box fitted with servomotors, and calibrated an Artillery Sidewinder X1 to print the parts.
HOPE Technik
SingaporeSpecialist vehicles and mechanical design.
- Mechanical Engineering InternMay 2019 – Jul 2019
- Worked with technicians to build a medical service vehicle and meet project milestones.
- Built a CAD model of an Isuzu truck in SolidWorks, and reviewed commercially available exoskeletons for a possible new project.
Projects
Selected work
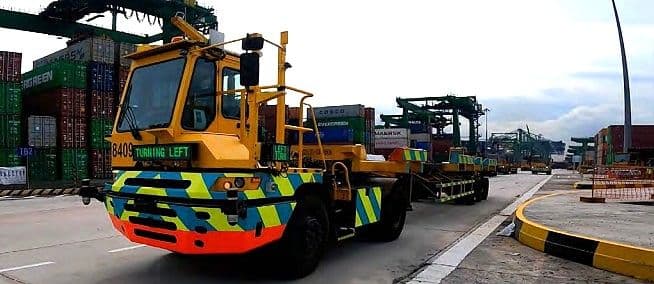
Venti Technologies
Path planning, remote operations, and autonomy-stack integration for driverless truck-trailers at seaports and railyards.
Hybrid A* · Remote operations · C++
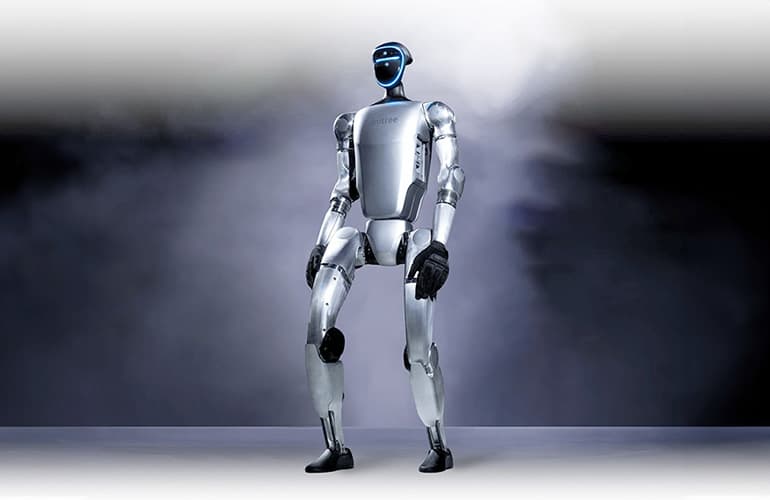
Whole-body locomotion for a Unitree G1
In progress — started September 2026
Graduate capstone with FieldAI: whole-body locomotion on a Unitree G1 for autonomous stair traversal and tool manipulation.
Humanoid control · Perception · Capstone
 Video
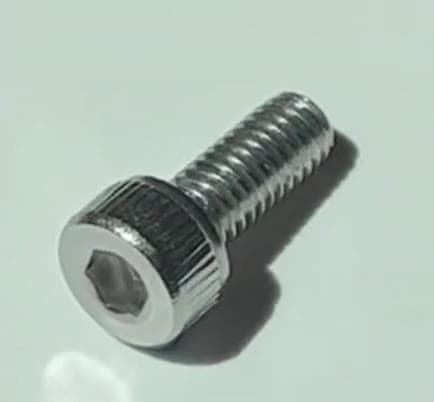
CNN-based screw classifier
End-to-end deep learning pipeline for screw identification from CAD renders and real video frames, served through a Telegram bot.
CNN · Transfer learning · Computer vision
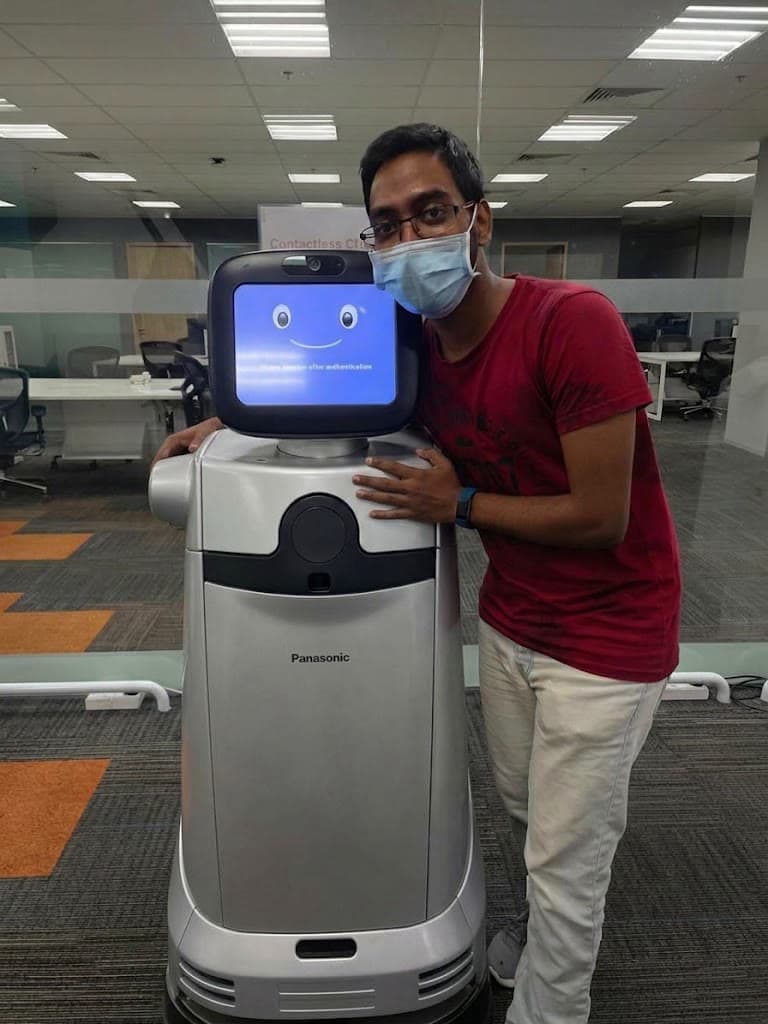
AMR navigation and ROS1 to ROS2 migration
ROS1-to-ROS2 migration for an autonomous wheelchair and a hospital delivery robot, with Nav2, region-based speed regulation, and Dubins docking.
ROS2 / Nav2 · Path planning
 Video
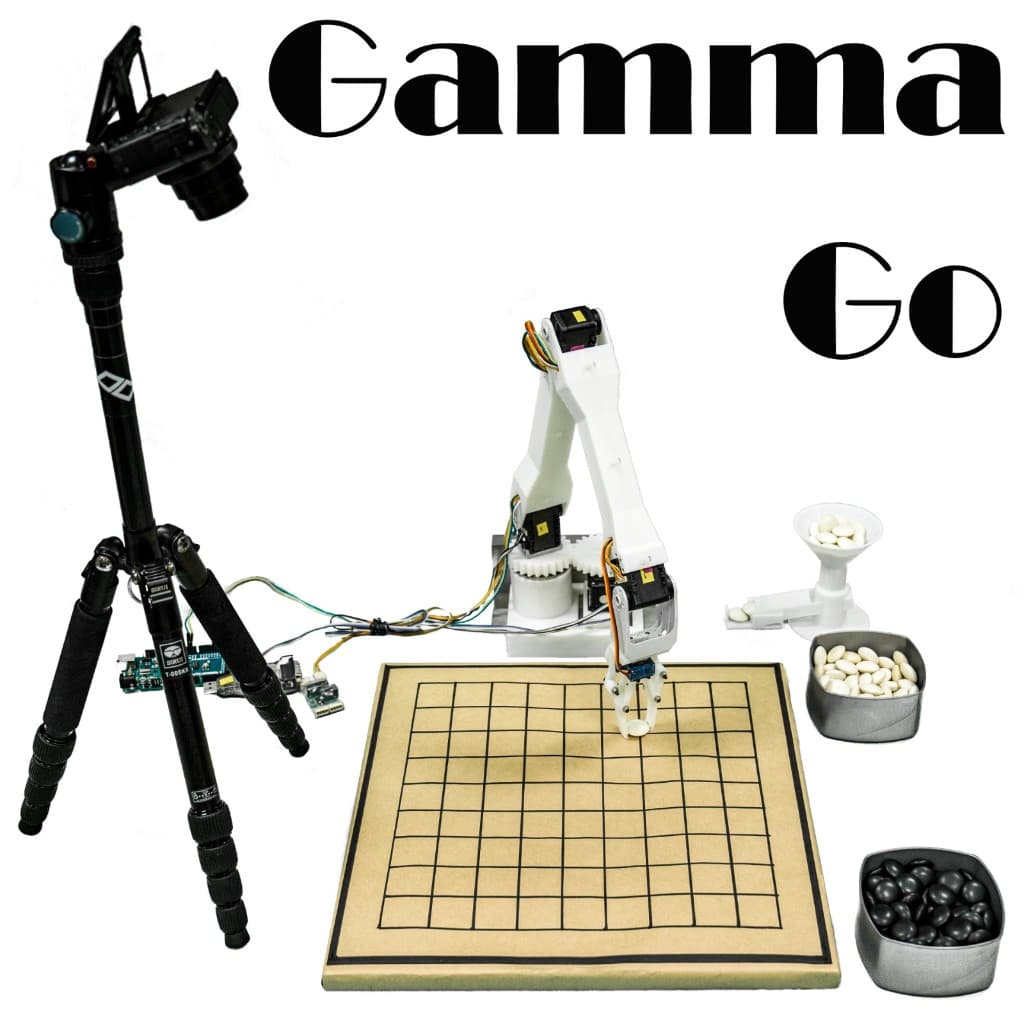
4-DOF real-time board-game-playing arm
Real-time 4-DOF arm that plays Gomoku, with a custom inverse kinematics solver and ROS1 MoveIt. Best project in MA4825.
OpenCV · Inverse kinematics · MoveIt
Papers and labs
Research
Gravity compensation for the HEBI X5-4 actuator
Aug 2021 – May 2022NTU Final Year Project (Honours). Multivariate regression gravity-compensation algorithm for the HEBI X5-4 actuator in Python, with 98.9% accuracy, a 67% reduction in trajectory error, and safer human-robot interaction at 50% position gain.
Conference publication: Open access in educational research
Presented Apr 2022Grandhi, Vamsi. “Open Access in Educational Research: Insights from Large-scale Analysis in the Past 40 Years.” 2022 Annual Meeting of the American Educational Research Association, San Diego, CA, 21 April 2022.
Neural signal classification from calcium imaging
Aug 2020 – May 2021URECA research scholar. Built generalized linear models over calcium imaging data from mouse behavioural studies, using correlation analysis and FFT for feature extraction from high-dimensional time series.
Personally
What I enjoy
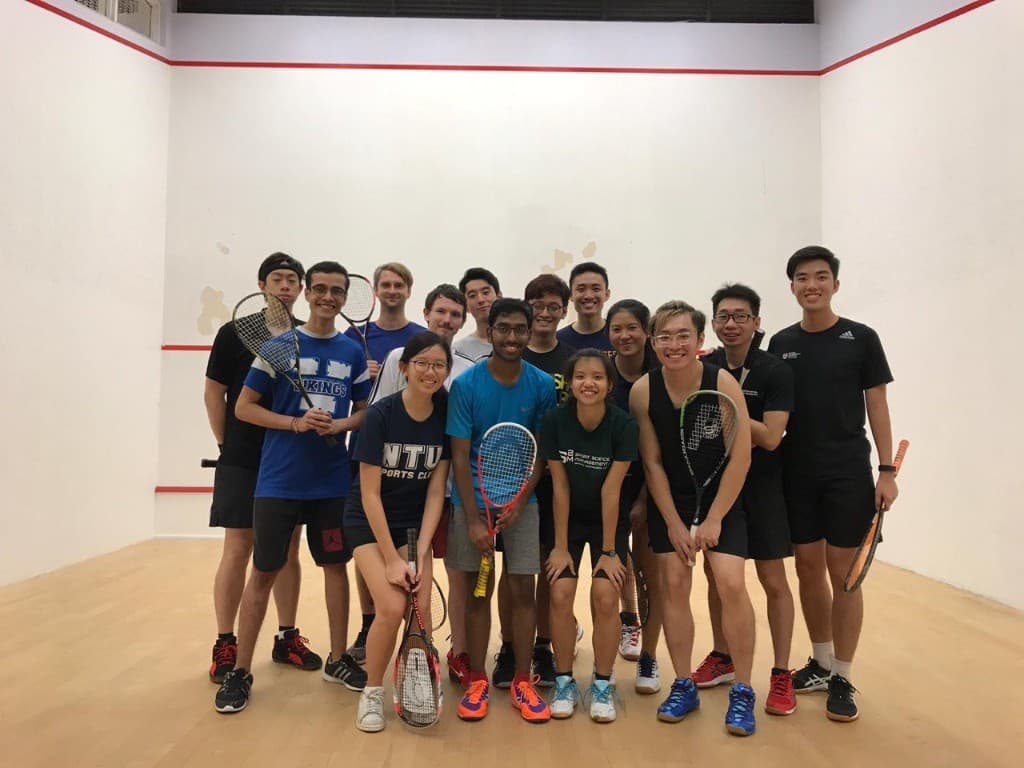
Squash
My go-to way to stay active.
Scuba diving
A new hobby I picked up recently. I'm enjoying learning something completely different.
Sitcoms
Easy to watch and easy to rewatch. My default way to unwind.