AMR navigation and ROS1 to ROS2 migration
ROS1-to-ROS2 migration for an autonomous wheelchair and a hospital delivery robot, with Nav2, region-based speed regulation, and Dubins docking.
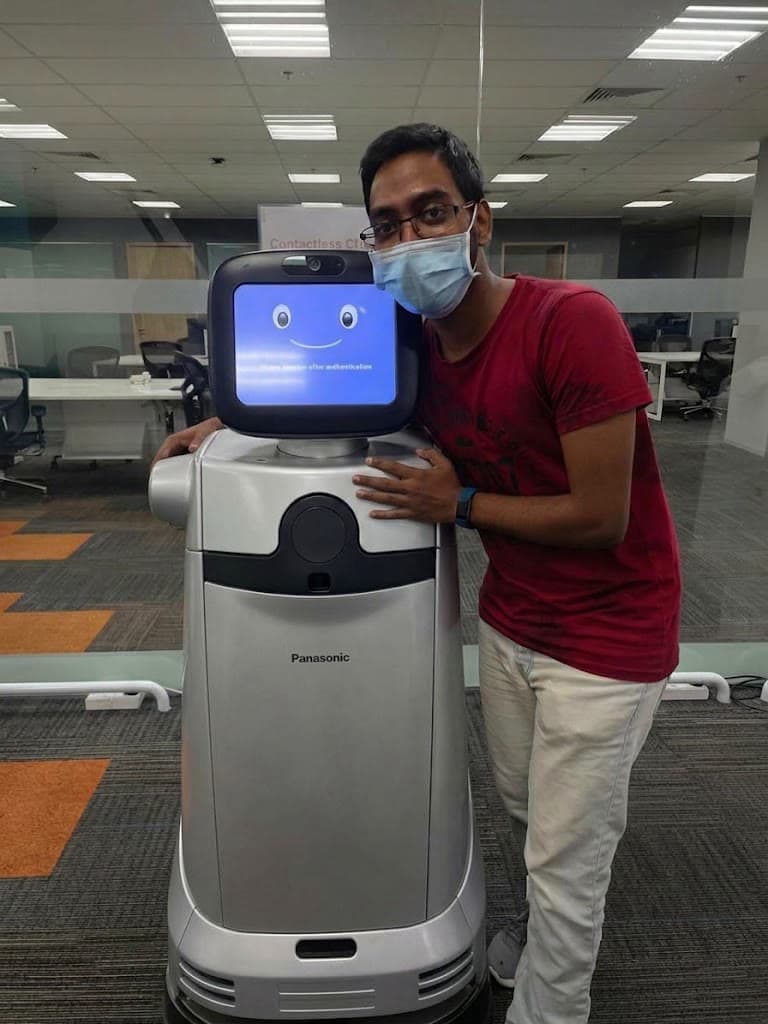
- Role
- Research Intern, Autonomous Mobile Robot Navigation
- Where
- Panasonic R&D Center Singapore
- When
- Jan 2021 – Aug 2021
- Stack
- ROS1, ROS2, Nav2
What I did
- Converted the ROS1 navigation stack of an autonomous wheelchair and the Hospi medication-delivery robot (1.3 m) to ROS2, finishing in about two months against a six-month estimate.
- Integrated Nav2 with region-based speed regulation, added dynamic obstacle detection and avoidance, and implemented a Dubins path planner for autonomous charging dock approach.
Outcome
- ROS1-to-ROS2 migration in about two months against a six-month estimate.