In progress — started September 2026
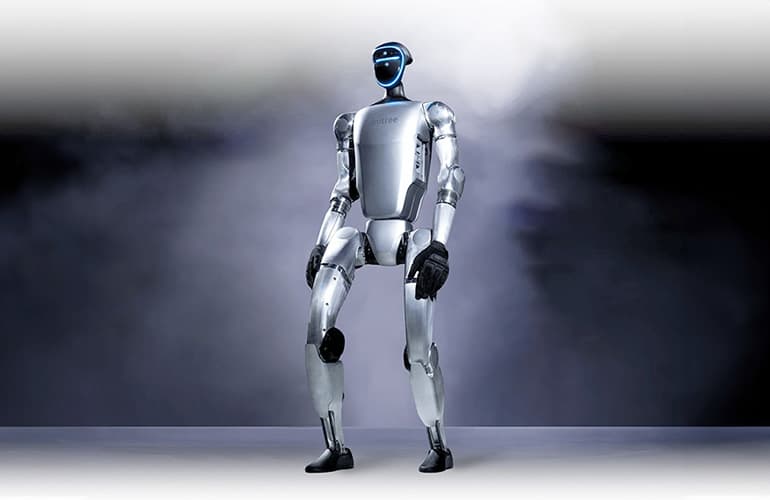
Whole-body locomotion for a Unitree G1
Graduate capstone with FieldAI: whole-body locomotion on a Unitree G1 for autonomous stair traversal and tool manipulation.
- Role
- Team member
- Where
- CMU MRSD Graduate Capstone project, in collaboration with FieldAI
- When
- Sep 2026 – present
- Stack
- Unitree G1
What I did
- Working on whole-body locomotion for a Unitree G1 as a graduate capstone with FieldAI, supporting autonomous stair traversal and tool manipulation, and exploring perception and humanoid control.