Venti Technologies
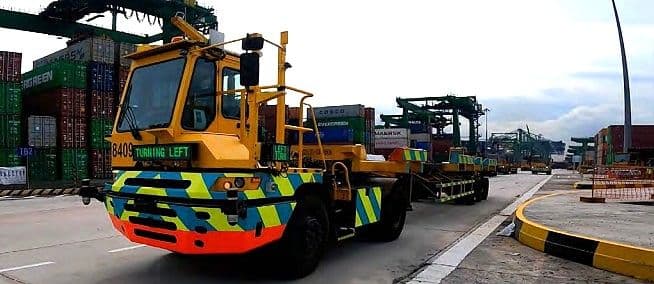
Path planning, remote operations, and autonomy-stack integration for driverless truck-trailers at seaports and railyards.
- Role
- Senior Software Engineer, Planning and Control · Software Engineer, Planning and Control
- Where
- Venti Technologies
- When
- Jul 2022 – Aug 2026
- Stack
- C++, ROS2, MQTT, Cap'n Proto, Bazel, Linux
Motion planning
- Engineered perpendicular parking for a non-holonomic truck-trailer system, resolving perception, localization, and control integration issues; optimized Hybrid A* heuristics and costmaps, reducing planning time from 60s to under 500ms.
- Implemented dynamic reverse path planning, a core planning capability for a $1M+ pilot deployment in the USA, extending Venti's autonomy stack to a new market and traffic environment.
- Spearheaded Hybrid A* path planning for non-holonomic truck-trailer overtaking at unsignalized junctions in a mixed-traffic port environment, reducing operator interventions by 15%.
Remote operations and route recommendation
- Built an intelligent route recommendation system using live sensor feeds and a proprietary remote-operations interface, decreasing vehicle stalls and improving uptime by 9.89%.
- Co-developed a remote operations system in a 3-member team spanning UI, planning, perception, and localization, using MQTT and Cap'n Proto for real-time autonomous vehicle monitoring, accelerating driverless production deployment.
- Managed software integration of Venti's autonomy stack at the world's largest transshipment hub by co-designing with the Port of Singapore Authority (PSA), contributing to the majority of 2024 company revenue.